Stanford robot cleans kitchen with AI in direct control
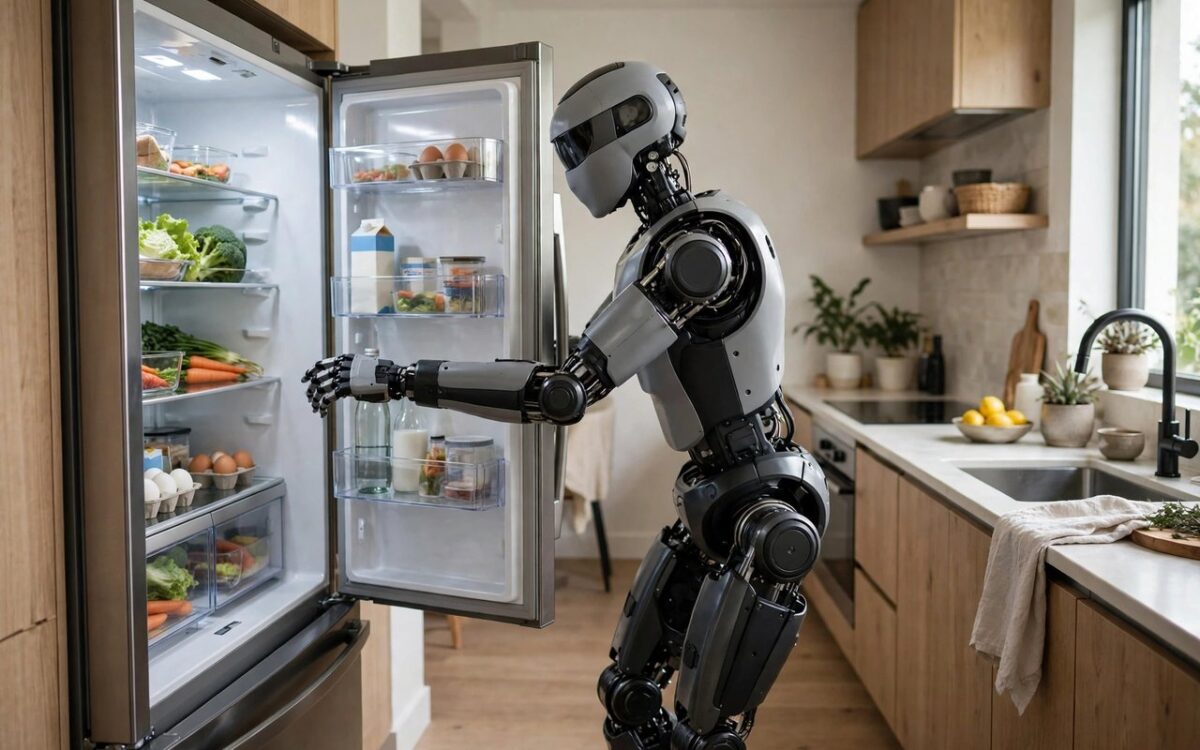
Stanford and Caltech researchers have built HomeBody, a system that lets a humanoid robot clean an unfamiliar kitchen with no trained control layer between the AI and the robot’s motors.The system connects OpenAI’s GPT-6 Astra directly to a Unitree G1 robot. Instead of a learned intermediary, the language model calls a library of skills such as grasping, navigating and opening drawers.First the robot explores the room. It builds a digital twin of the space inside Nvidia’s Isaac Sim and logs object locations into a spatial memory.
That lets it find items even after they leave its camera view.In tests, the robot gathered coffee bags, threw out spoiled milk and juice cartons, and retrieved medicine from a closed drawer it had to locate from memory. The code has been published on GitHub.The team reports limits: the model’s latency slows the action loop, finger servos overheated during long runs, and running a large model in the loop is costly. It is a research demo, not a product.
Related stories
View all →
Eloelo launches Dolphin AI video tool at FICCI FRAMES
Creator platform Eloelo has launched Dolphin AI, a new tool for making videos with artificial intelligence. The launch took place at FICCI…
Anthropic Launches AI Defense Program for Critical Infrastructure
Anthropic is launching a program that puts its most powerful AI models and engineers with companies protecting power grids and water utilities.
Chinese AI Firms Published Safety Tests for Just 3.6% of Models
A SemiAnalysis review found Chinese AI developers published model-specific safety tests for only 31 of 857 model releases.
Khabar 24h Editorial Desk — our explainers are prepared by the Khabar 24h editorial team using AI-assisted research tools, and every piece is reviewed by a human editor before publishing. We do not claim original reporting: our work is turning complex topics into simple, accurate summaries. Spotted an error? Write to contact@khabar24h.com — our corrections policy aims for same-day review.
More from this author →
Leave a Reply